My name is Yiyang Ge. I am a first-year Master Student in Mechanical Engineering at University of Washington.
My research interests center on robot learning and dexterous manipulation. I have explored these areas from two complementary perspectives: visuotactile perception for manipulation, and reinforcement learning for improving policies on real robots. My long-term goal is to build robotic agents with human-level dexterity.
📝 Publications
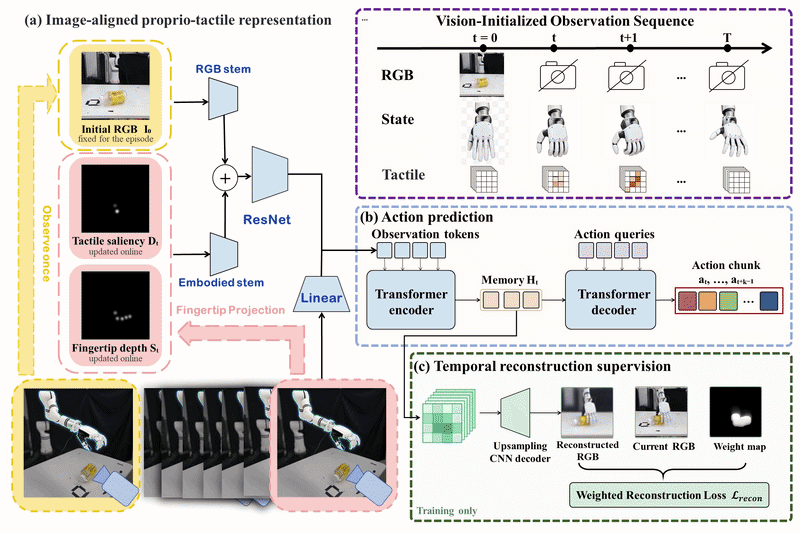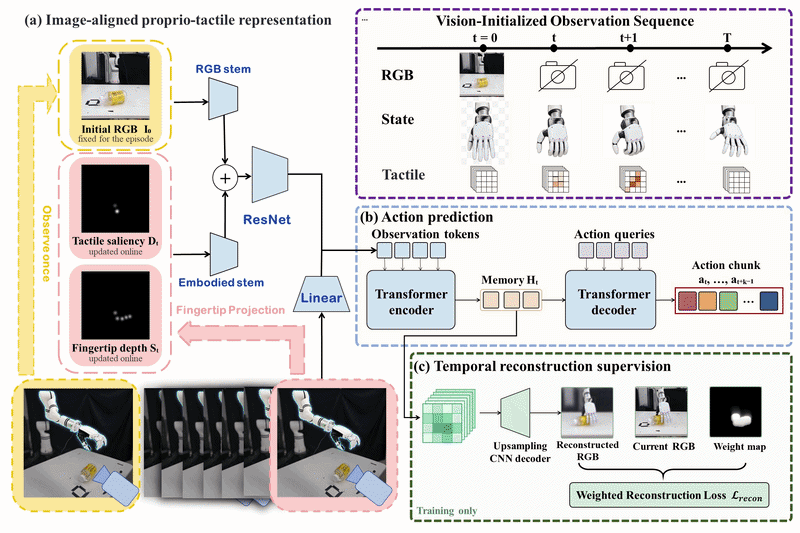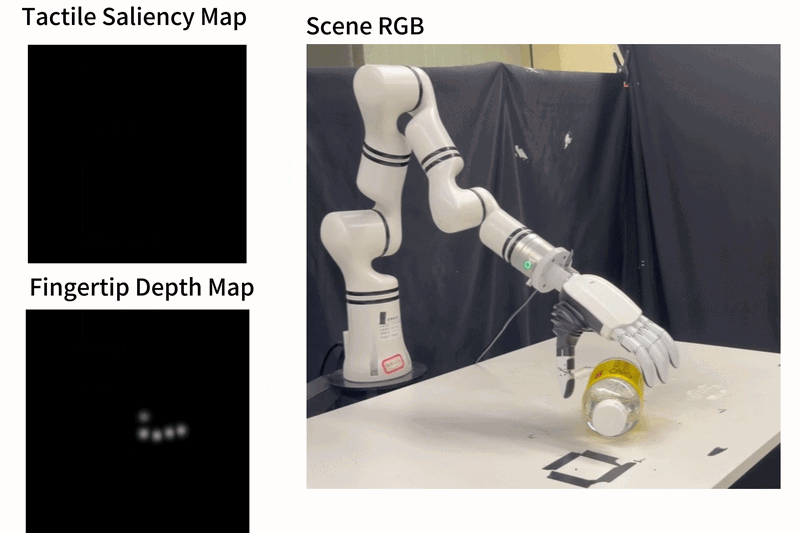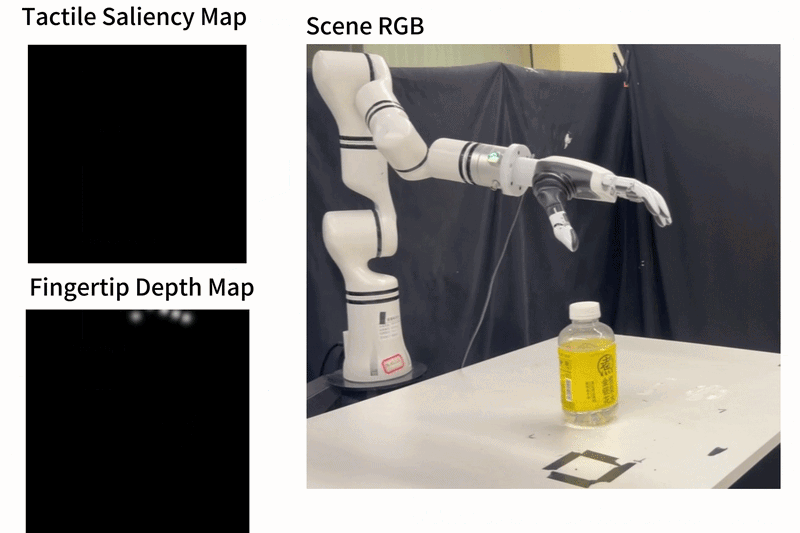
Vision-Initialized Manipulation with Image-Aligned Proprio-Tactile Feedback
Yiyang Ge, Sihan Bai, Ke Jin, Binghen Zhang, Siyun Wang, Qi Ye.
- Submitted to ICRA 2027
- Studied Vision-Initialized Manipulation setting where policy uses a single initial image and subsequently operates using only tactile and proprioceptive feedback.
- Projected fingertip positions and tactile measurements into the initial camera frame to construct image-aligned fingertip-depth and tactile-saliency representations, enabling fusion of temporally mismatched sensory inputs.
- Designed an auxiliary current-image reconstruction objective, weighted by temporally aggregated fingertip occupancy, to emphasize interaction-relevant regions during representation learning.
- Evaluated the method on four simulated manipulation tasks and a real-world bottle-liftup task, achieving a 29% relative improvement in mean success rate over imitation-learning baselines under the same visual constraint and approaching the performance of policies with updated vision on selected tasks.
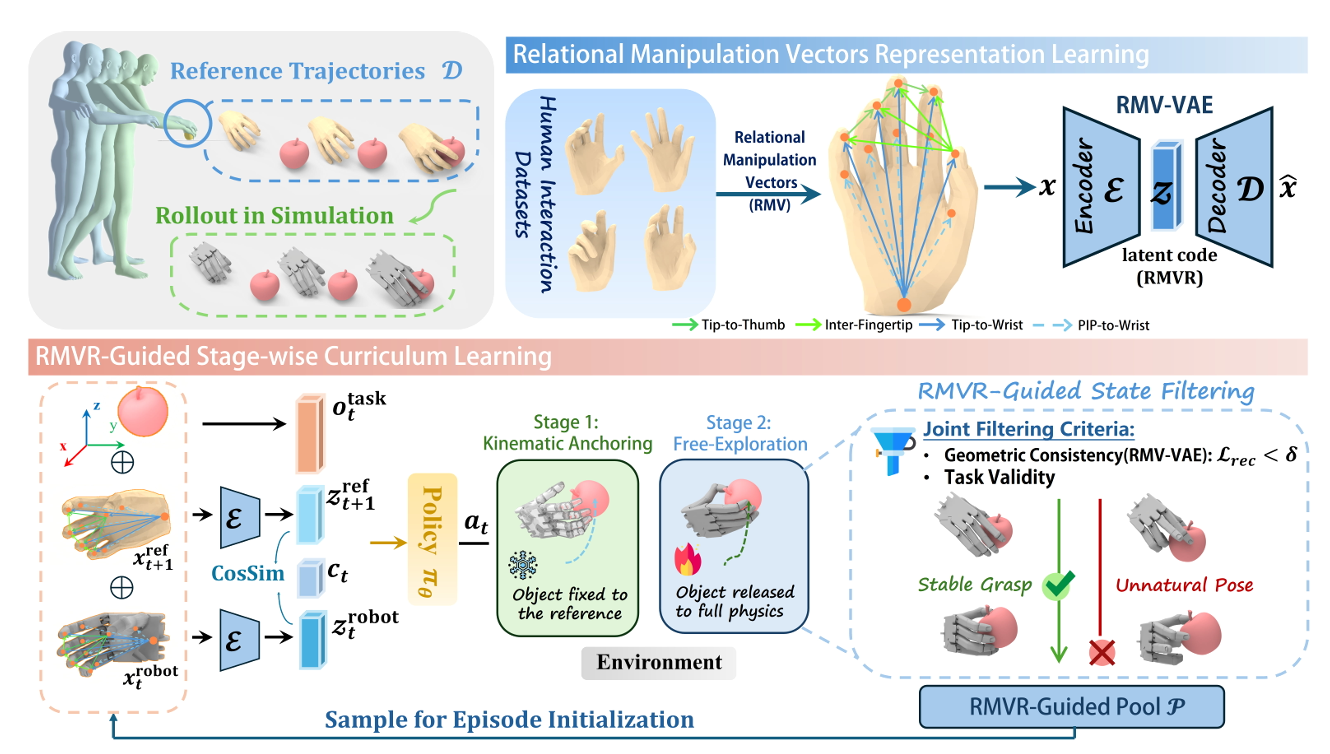
Relational Dexterity: Transferring Human Dexterity Via Relational Geometric Prior
Jiaying Chen, Bingheng Zhang, Qingtao Liu, Yiyang Ge,Wenzhe Ouyang, Anjun Chen, and Qi Ye.
- Accpted at IROS 2026
- Investigated retargeting human hand motion-capture data into task-feasible trajectories for dexterous robot hands by reinforcement learning with hand geometric prior.
- Reproduced and evaluated the ManipTrans baseline, conducted comparative experiments, and contributed to method refinement.
📝 Projects
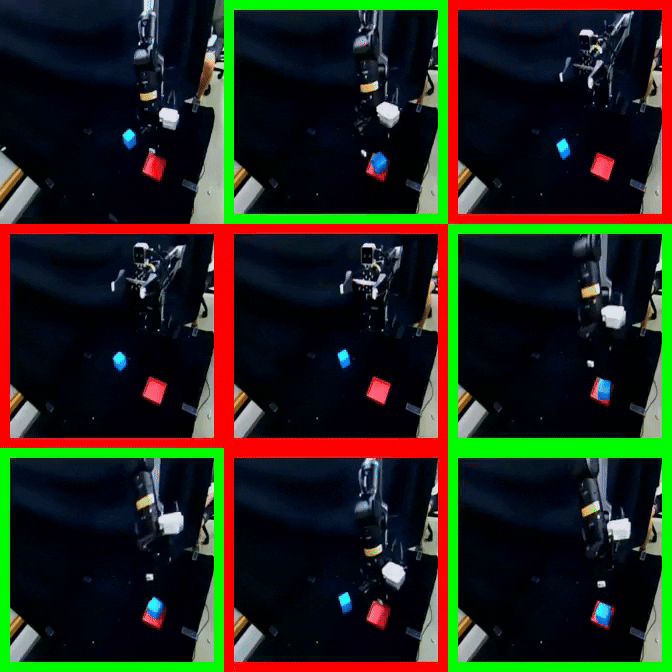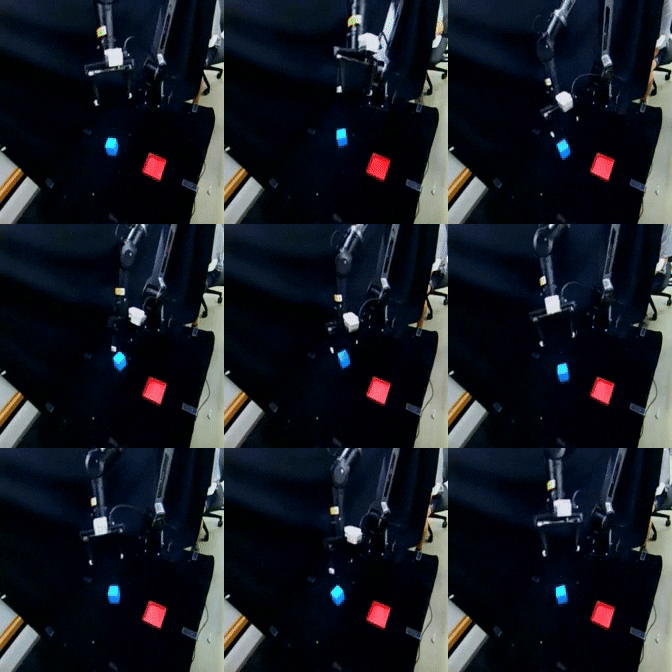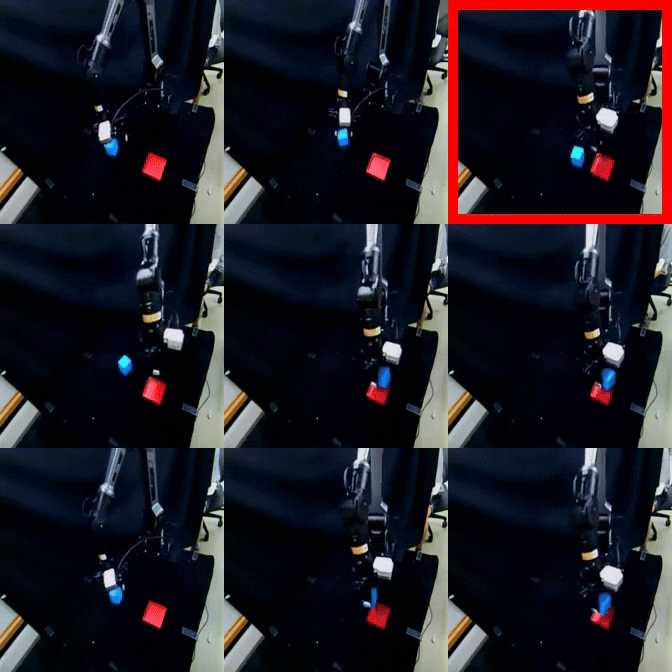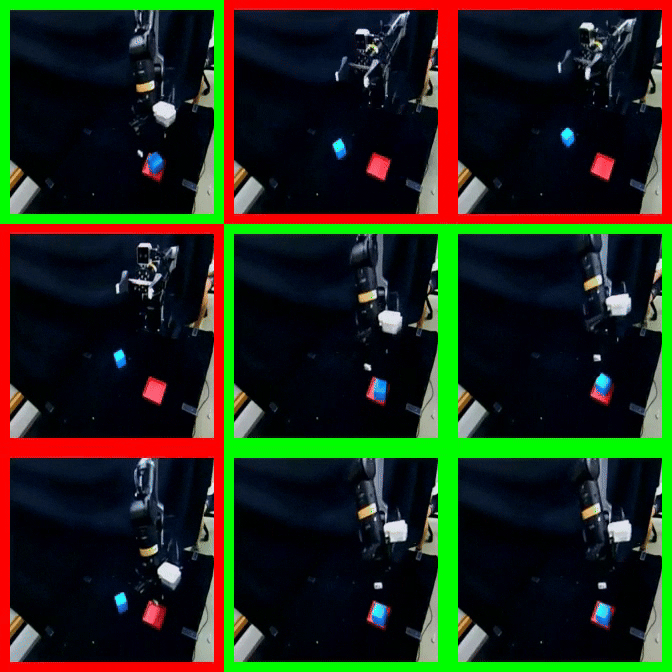
Research on Reward Model in Real-World Robot Reinforcement Learning
- Investigated sample-efficient offline robot reinforcement learning using learned visual reward functions.
- Fine-tuned a pretrained Valine-Implicit Pretraining(VIP) model with a small set of demonstrations to estimate task rewards.
- Integrated the learned reward model with Reward-Weighted Regression (RWR) to enable offline policy improvement without manually designed rewards.
- Evaluated the approach in ManiSkill and deployed it on an AgileX Piper robot arm for a real-world cube pick-and-place task.
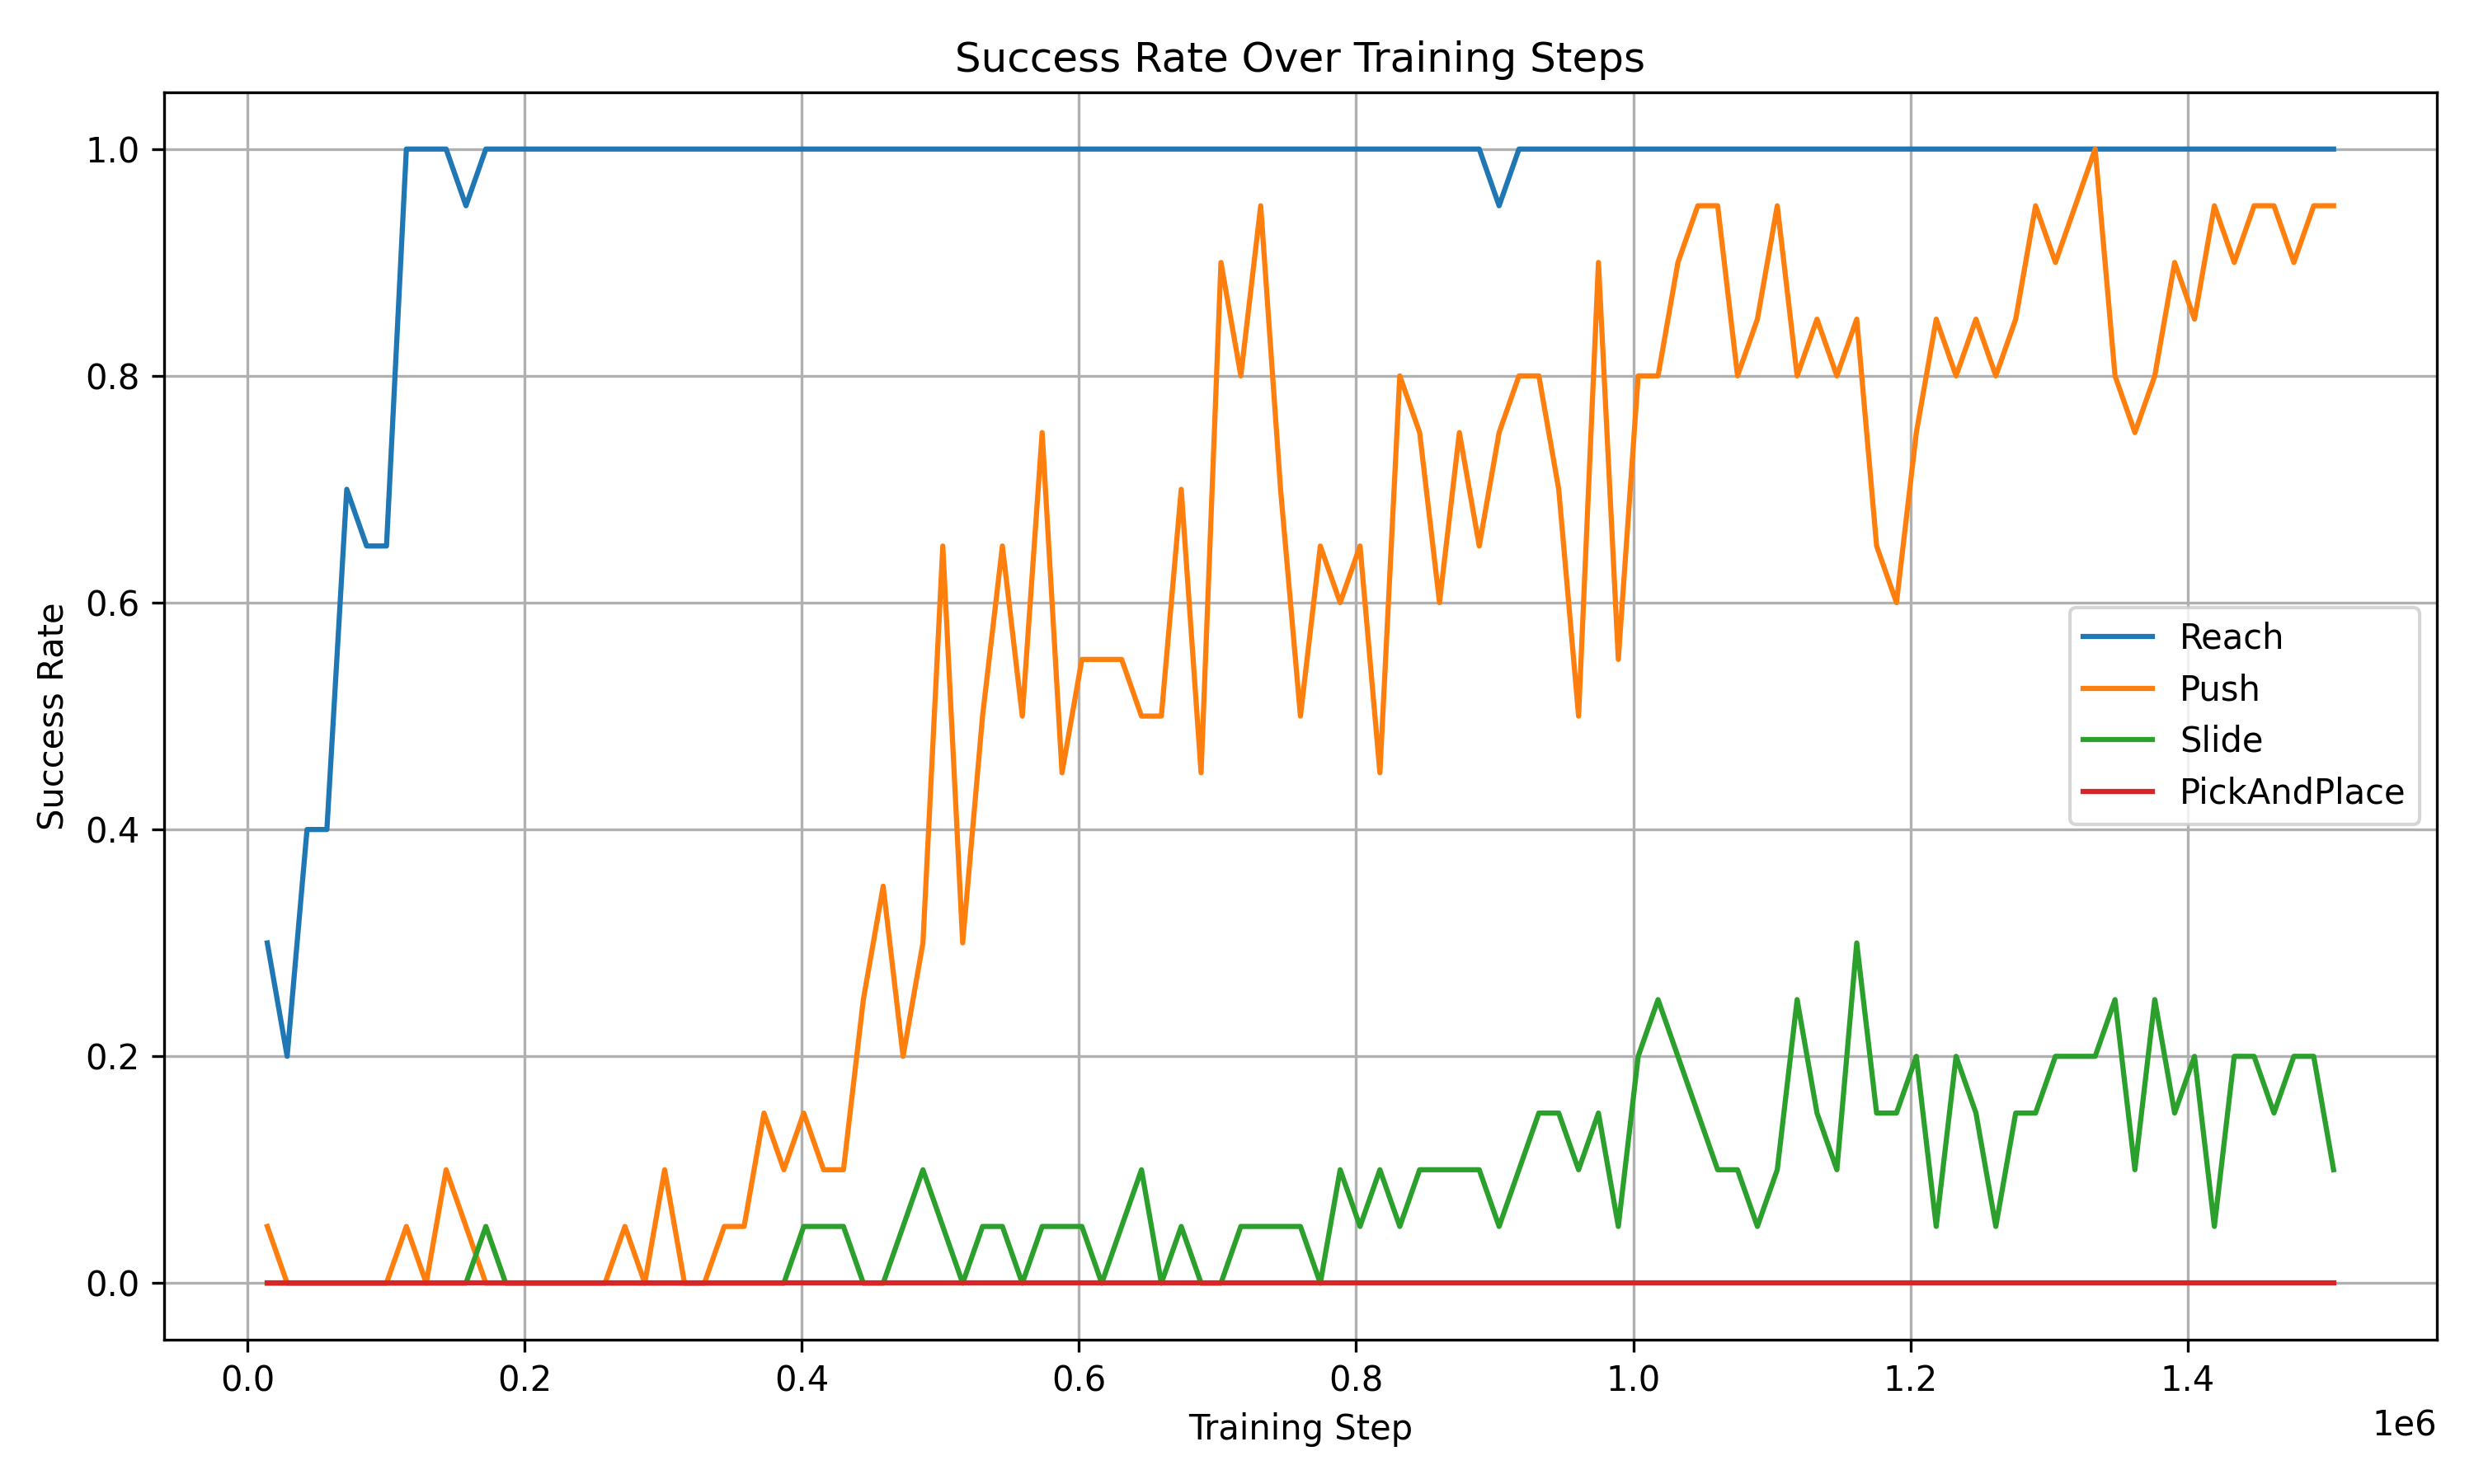
A FiLM based Multi-task Reinforecement Learning
- This project was conducted as part of the course CS 4756: Robot Learning at Cornell University.
- Integrated a Feature-wise Linear Modulation (FiLM) layer into a multi-task RL model, allowing the task encoding to exert more direct control over the network.
- Observed that the FiLM-enabled model outperformed the vanilla multi-task learning baseline, which only concatenated a one-hot task encoding to the input.
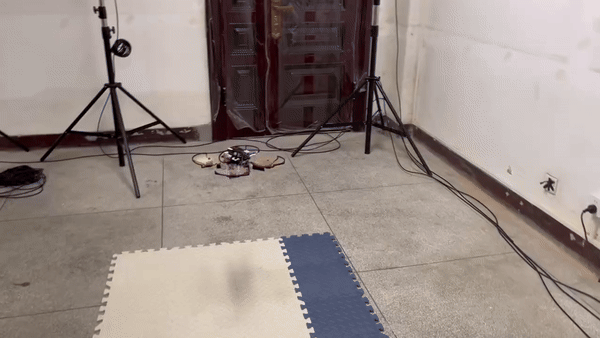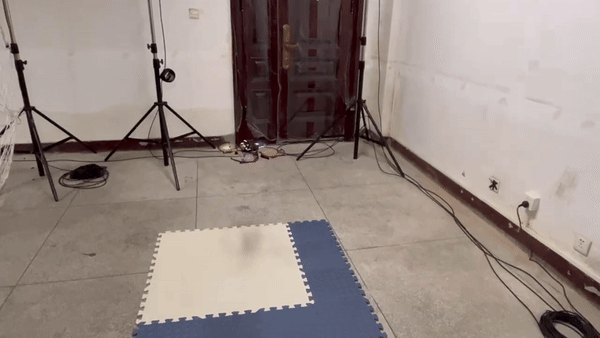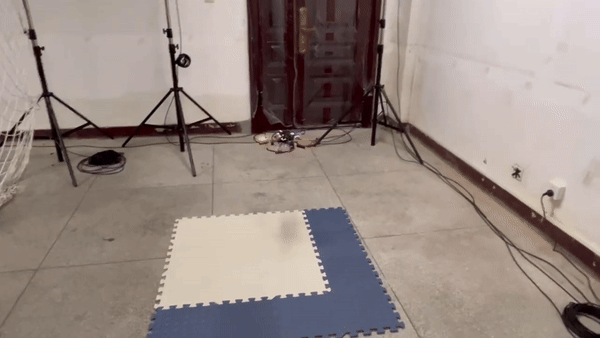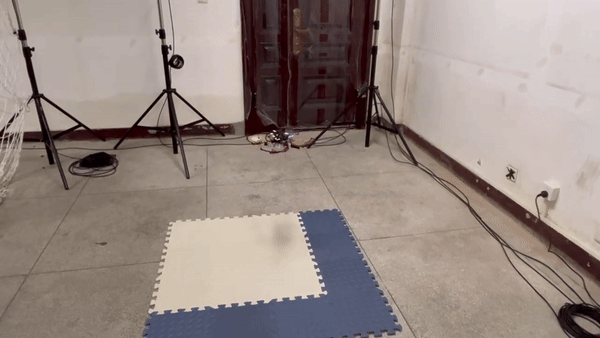
Quadropter Building and Autonomous Hovering
- Build a quadrotor and its controller from zero, and automatically hover it under motion capture system
- Implementing basic cascaded PID controller and SE(3) controller.
- Practice hardware, PCB design and assembling.
📖 Educations
- 2026.09 - now, University of Washington,Seattle. Master, Major: Mechanical Engineering
- 2022.09 - 2026.6, Zhejiang University. Junior, Major: Automation
- 2025.01 - 2025.05, Cornell University. Exchange student, Major: ECE
🎖 Honors and Awards
- 2026 Outstanding Graduate of Zhejiang University
- 2023,2025 Second Prize Scholarship of Zhejiang University <!– - 2023.12 Second Prize of Theoretical Physics Competition for University Students in Zhejiang Province
- 2024.04 First Prize in Zhejiang University Robot Competition (Transport Vehicle Track) –>